Convex Optimization-Based Trajectory Planning for Quadrotors Landing on Aerial Vehicle Carriers
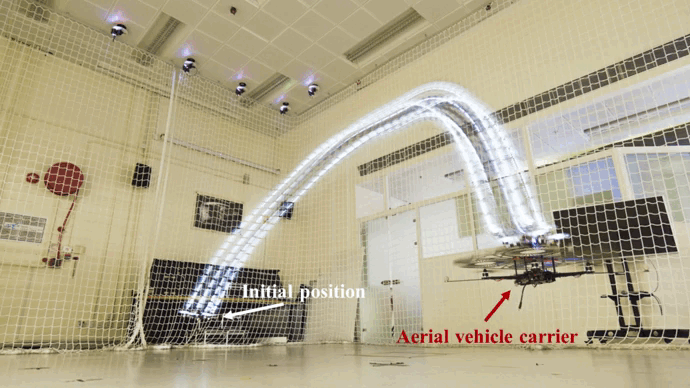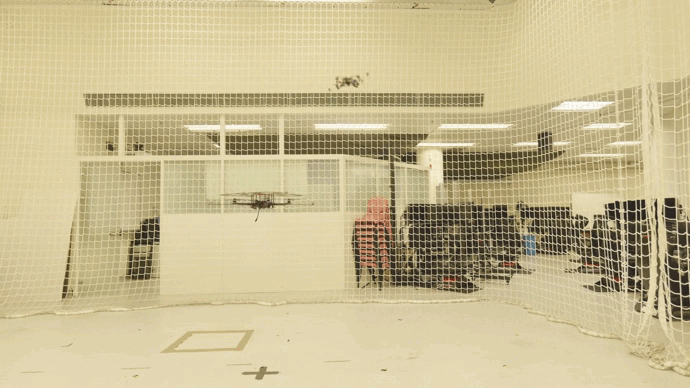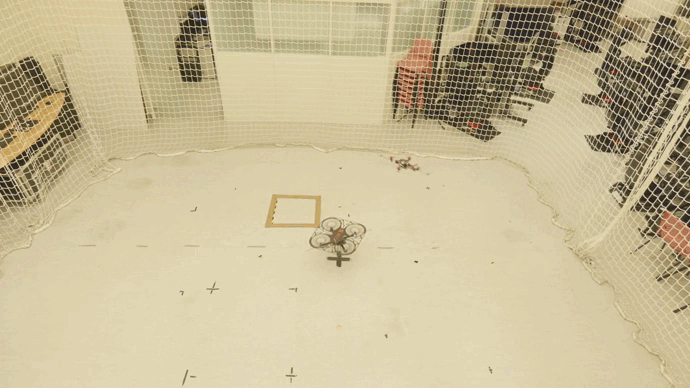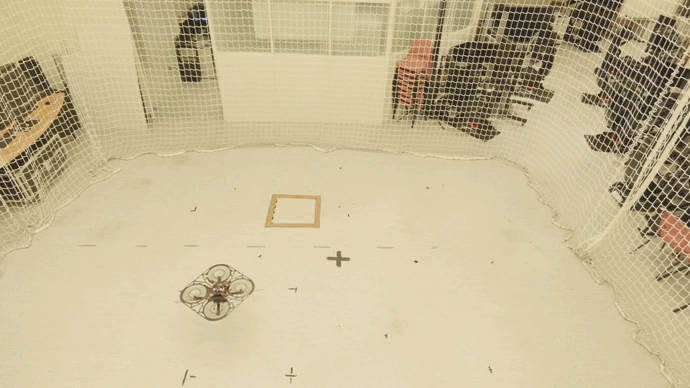 Quadrotor landing on AVCs
Abstract
This paper presents a novel trajectory planning algorithm for quadrotors landing on aerial vehicle carriers (AVCs). The algorithm involves a quadrotor trajectory planning method based on the lossless convexification (LC) theory and a sequential convex programming (SCP) method enabling quadrotors to autonomously land on both static and moving AVCs in a three-dimensional space. By incorporating landing cone constraints, the safety of the quadrotor during landing is ensured. The LC method transforms the original nonconvex optimal control problem (OCP) into a convex optimization problem, enabling the efficient computation of a 3-degree-of-freedom (3-DoF) safe landing trajectory. The designed SCP algorithm utilizes the 3-DoF trajectory as an initial guess and iteratively solves convex subproblems to obtain a safe, agile, and accurate landing trajectory for the complete 6-DoF quadrotor dynamics. Real-world experiments validate the effectiveness and real-time performance of the proposed method.
Zhipeng Shen
Researcher
Researcher working on VLA/WAM architectures and hierarchical decision-making for autonomous driving.