UAV-Based Balcony Logistics for Fourth-Generation Residential Buildings
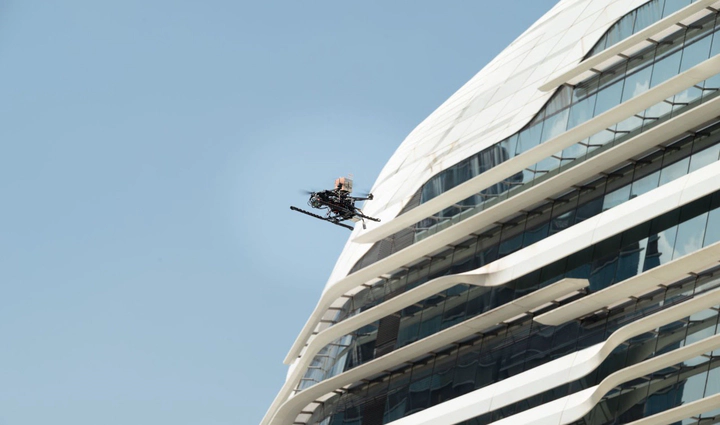 Student project with EHang and Huafa Group
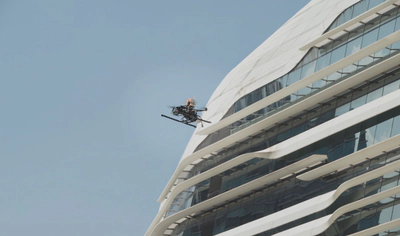
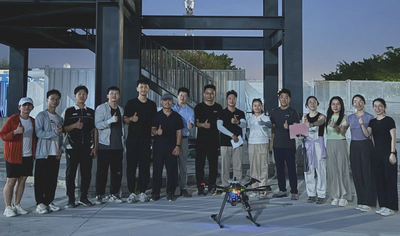
As the student project lead, I developed a balcony-delivery UAV using radar and RTK positioning for autonomous entry into residential balconies and parcel delivery. The team completed system integration and on-site tests in Zhuhai from April to November 2024.
I led the path-planning and motion-control development and fused radar-based obstacle avoidance with RTK localization to improve positioning accuracy and flight safety.
Zhipeng Shen
Researcher
Researcher working on VLA/WAM architectures and hierarchical decision-making for autonomous driving.