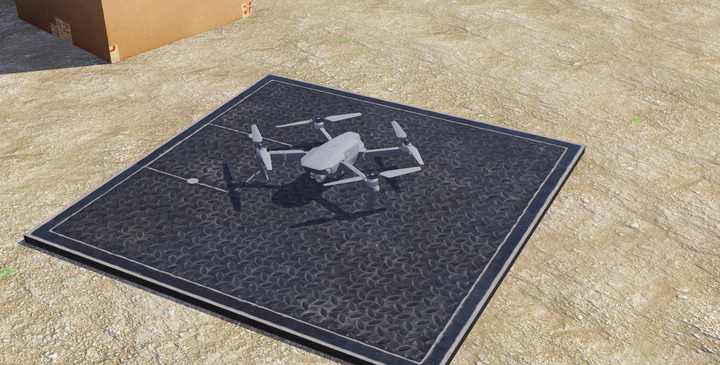
 Open-source quadrotor control framework
AIMS Drone Control is an open-source ROS/Python framework for quadrotor simulation and real-world flight control. It supports Webots simulation and PX4 experiments through MAVROS and Vicon-based state estimation.
The project implements acados-based nonlinear model predictive control (NMPC) and linear quadratic regulation (LQR) for trajectory tracking, waypoint flight, takeoff, and landing, providing a unified simulation-to-real workflow.
Zhipeng Shen
Researcher
Researcher working on VLA/WAM architectures and hierarchical decision-making for autonomous driving.